Deployment-specific Sim2Real adaptation
2.38% → 95.24%
n ≈ 42 inferred · 1/42 → 40/42 · split not independently verified
Baseline2.38%
Adapted95.24%
Robot-image accuracy after deployment-specific Sim2Real adaptation
The model looked strong on curated data and degraded sharply on robot-camera images. The recovery came from treating domain shift as a deployment problem, not a footnote.
Why it matters: the adaptation restored useful robot-camera performance under changed lighting, viewpoint, scale, and background conditions.
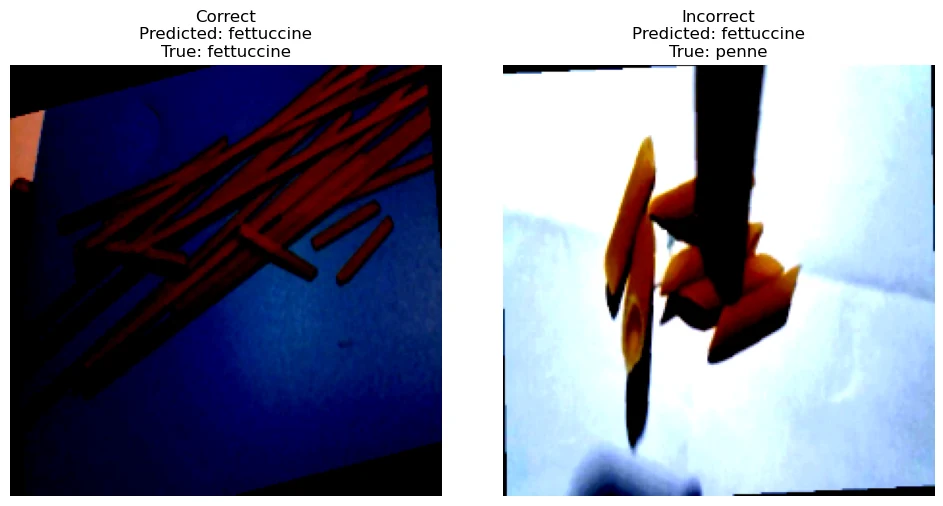
Robot-camera predictions · published team-level result
Evaluation context
- Counts
- Reported percentages are consistent with 1/42 correct before and 40/42 after adaptation; the linked camera-image folder contains 42 files. The original evaluation labels are not published.
- 95% Wilson CI
- Baseline 0.42–12.32% · adapted 84.21–98.68%. Binomial intervals conditional on the inferred n=42 denominator; not independently reproducible without ground-truth labels.
- Evaluation set
- 42 robot-camera images are public. The exported folder does not preserve ground-truth class labels, class balance, or the split-generation record.
- Attribution
- Collaborative team-level result. Public evidence includes the 42-image evaluation folder, exported notebook figures, and deployment recording.